
Supervisor:
Mosse Sjaastad
Kjetil Nordby
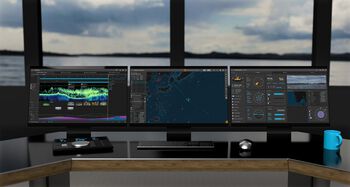
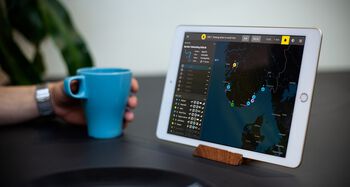
Maritime industries are complex workplaces were human and environmental safety is critical. Innovations in the field of Artifical Intelligence, wireless technology and robotics are enabling new ways to perform dangerous or repetitive tasks at sea without having people onboard. Small Unmanned Surface Vehicles (USV) can carry sensors in ways that before have been too expensive or risky with traditional methods and offer great advantages in data collection from our oceans. Gathering of knowledge and data over long periods of time is key to understanding our oceans and for a sustainable future.

My work is building on the OpenBridge design guidelines, developed at the Ocean Industries Concept Lab, at AHO. For more detailed info, please check out the project: thomaswangj.com/voyage.


Contact
Thomas Wang Johannesen / thomaswangj@gmail.com / thomaswangj.myportfolio.com